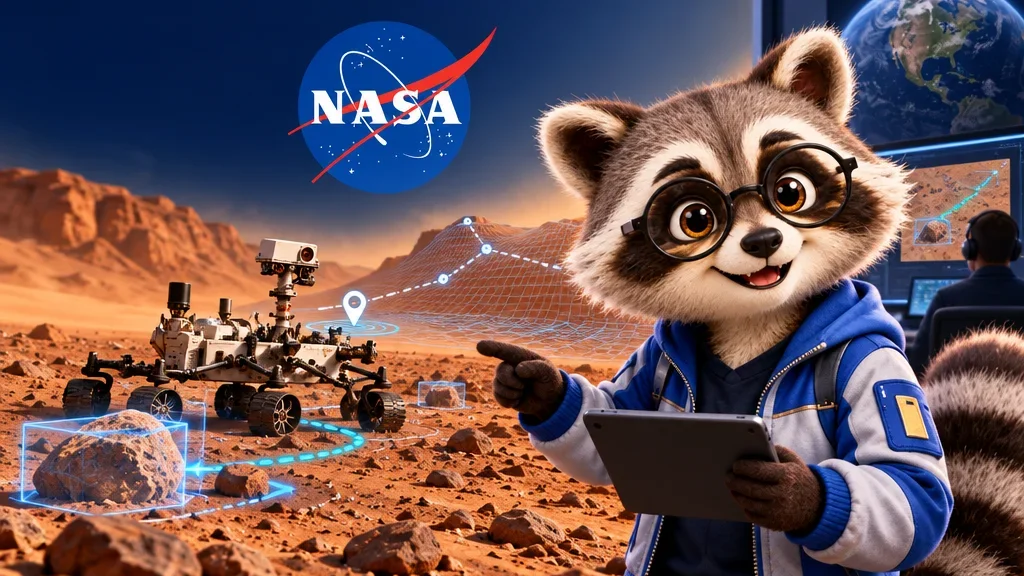
On Mars, a waypoint can tell Perseverance where to go without telling it how to get around every boulder. That gap is where the rover’s onboard navigation earns its keep. NASA’s Jet Propulsion Laboratory reports that Perseverance reached 45.22 kilometres on October 11, 2026, passing Opportunity’s distance record. It used AutoNav to evaluate terrain on more than 90% of that journey.
Driving and knowing where you are
AutoNav uses images taken while the rover is moving to build a 3D hazard map and steer between waypoints set on Earth. After a long drive, small errors can add up in the rover’s estimate of its position. Mars Global Localization lets it check that estimate independently by matching a panorama from its navigation cameras against orbital imagery.
Where Claude entered the picture
In two December 2025 demonstrations, JPL used Claude models on Earth to generate waypoints from orbital imagery and slope data. Engineers ran the commands through a digital twin before uplinking them. The drives covered 210 and 246 metres. For a mission team, the distinction is practical. Generative AI can help prepare the route on Earth, while onboard navigation handles the terrain the rover actually encounters.