A robot does not have to make every attempt at grasping a box in the physical world. Simulation can help researchers run many trials under different conditions. NVIDIA announced the general availability of Isaac Lab 3.0 on October 21.
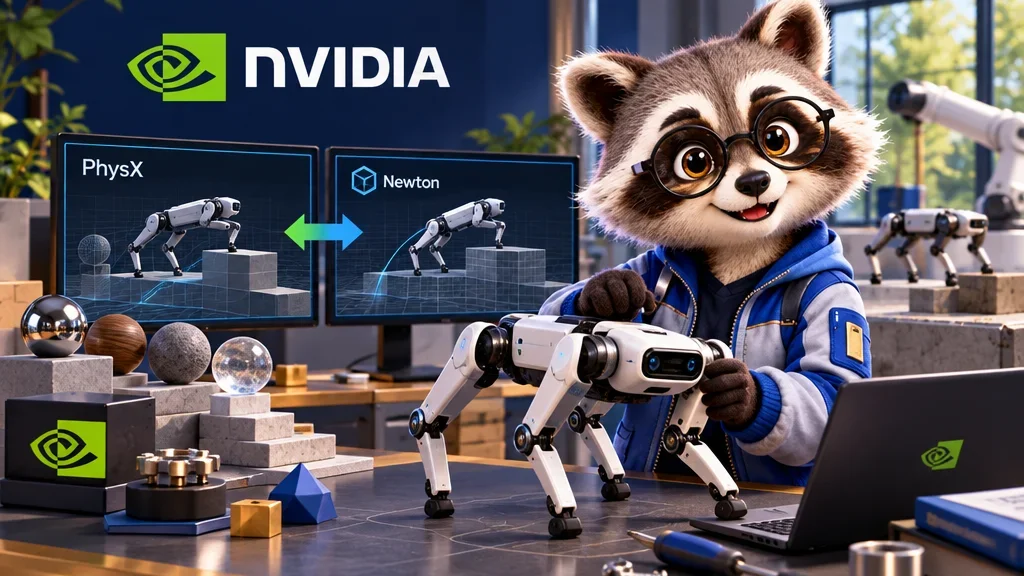
What do Newton and PhysX provide?
The open-source framework trains and refines robot policies using multi-GPU workflows from desktops to data centers. NVIDIA lists Newton and PhysX among its supported physics engines. The Isaac Lab documentation describes shared asset, sensor and scene interfaces across backends. Supporting Newton does not mean PhysX has been removed.
From simulation to a real robot
A physics engine calculates motion and interactions with objects in a virtual environment. Developers can use that environment to train and evaluate behaviors across tasks and conditions. Success in simulation does not automatically guarantee the same result on a physical robot: hardware, sensors and object behavior can differ.
Think of Isaac Lab as one tool in a development and evaluation workflow, with physical testing still needed to check how a policy transfers.